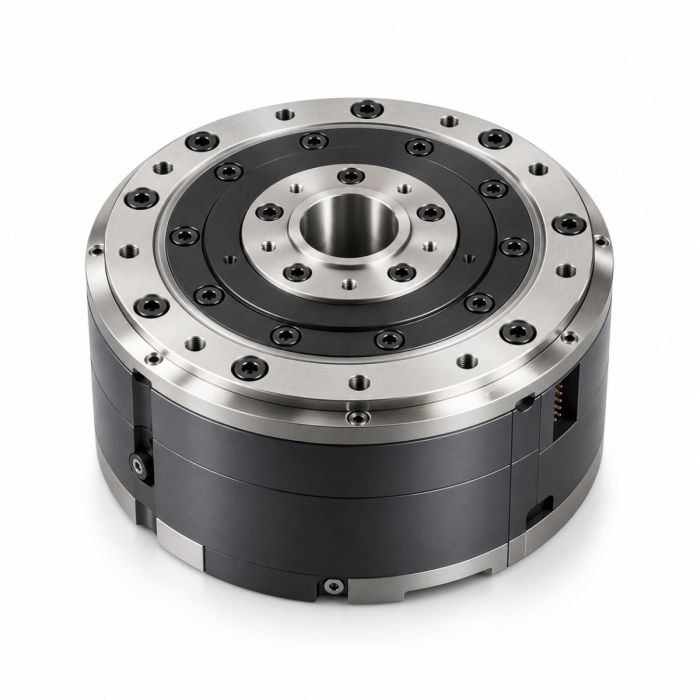
Xynova PR20-102-130-HS Rotary Actuator
In stock
- BRAND:
- XYNOVA
- MODEL:
- PR20-102-130-HS
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- Xynova-PR20-102-130-HS
Xynova PR20-102-130-HS Rotary Actuator
When a humanoid arm mirrors a human operator, or places a part within a fraction of a millimeter, the limiting factor is often not torque. It is how quickly the joint responds and how finely the controller can see where it is. The Xynova PR20-102-130-HS is tuned for exactly that. It pairs a 150 rpm output with a 17 bit encoder, the finest feedback in Xynova's mid range, while still delivering 130 Nm of peak torque in a 1.2 kg module.
Key Features
17 Bit Position Feedback
A 17 bit encoder resolves 131,072 positions per revolution, twice the count of a 16 bit encoder. Finer feedback gives the controller more information to work with during slow, precise moves and smooth trajectory tracking. Xynova rates the module's repeatability at 0.1° or better.
150 rpm Output Speed
The 20:1 planetary reduction gives a no load output speed of 150 rpm, faster than any other Xynova module except the compact 25 Nm wrist joint. That speed supports quick reaching, rapid repositioning and natural, fluid arm motion.
130 Nm Peak Torque
Peak torque of 130 Nm provides solid headroom for shoulders and elbows carrying tools, objects or the weight of an extended forearm and hand.
Slim 59 mm Housing
At Ø102 x 59 mm, this is the shortest of Xynova's 100 mm class joints. A shorter axial length helps when packaging joints side by side in a shoulder or stacking them in a compact torso.
Adaptive Control and Thermal Design
Xynova pairs its in house planetary gearbox with a decoupled adaptive control architecture and AI driven parameter tuning. According to Xynova, the series also uses electromagnetic and thermal co optimization, a proprietary winding process and integrated cooling channels, with designs validated through CAE simulation and fatigue testing.
Xynova PR20-102-130-HS Specifications
| Specification | PR20-102-130-HS |
|---|---|
| Type | Planetary joint module |
| Input voltage | 48 V |
| Peak torque | 130 Nm |
| No load speed | 150 rpm |
| Gear ratio | 20:1 |
| Weight | 1.2 kg |
| Size | Ø102 x 59 mm |
| Encoder resolution | 17 bit |
| Repeatability | ≤0.1° |
PR20 vs PR21 at a Glance
| Feature | PR20-102-130-HS | PR21-100-140-HS |
|---|---|---|
| Peak torque | 130 Nm | 140 Nm |
| No load speed | 150 rpm | 130 rpm |
| Encoder | 17 bit | 16 bit |
| Length | 59 mm | 61.7 mm |
| Weight | 1.2 kg | 1.2 kg |
Choose the PR20 for speed, feedback resolution and a shorter housing. Choose the PR21 when the extra 10 Nm of torque is the deciding factor.
Applications
- Teleoperated humanoid arms: fast, finely resolved joints that track an operator's movements closely.
- Shoulder and elbow joints: responsive upper body motion with solid lifting torque.
- Precision placement tasks: assembly and pick and place work where position detail matters.
- Torso and neck rotation: quick, smooth turning in compact packages.
- Research arms: high resolution joints for motion studies and control algorithm development.
Who Should Buy the PR20-102-130-HS?
Buy this module if your arm or torso joint needs fast motion and fine position feedback, and 130 Nm of peak torque covers your load. It suits humanoid teams working on teleoperation and dexterous manipulation, researchers developing control algorithms, and arm builders who want responsiveness without stepping down in strength.
Which Should You Buy?
| If you need... | Choose |
|---|---|
| Fast, high resolution mid range joints | PR20-102-130-HS |
| A little more torque at the same weight | PR21-100-140-HS |
| A small, light wrist joint | PRH19-57-25-HS |
| High torque hips and knees | PR64-110-500 or PR43-120-600-HB |
Before You Buy
- Size the load first: confirm 130 Nm peak covers your worst case arm pose and payload with margin; if not, consider the PR21.
- Request continuous ratings: Xynova publishes peak torque only, so ask for rated continuous torque, rated current and duty cycle.
- Match your controller: confirm the communication protocol and that your control stack can use the full 17 bit feedback.
- Check packaging: request mounting drawings to plan how the Ø102 x 59 mm housing fits your shoulder or torso.
- Confirm the HS variant: ask what the "HS" suffix includes before ordering.
- Quote the full arm: request pricing for every joint in the limb together.
Pricing and Availability
The Xynova PR20-102-130-HS is sold by quote. Add it to your quote from this page with your quantity, and our team will reply with current price, cost details and lead time. The module carries a 12 month warranty, and availability depends on production allocation.
Frequently Asked Questions
How much torque does the Xynova PR20-102-130-HS produce?
The PR20-102-130-HS delivers 130 Nm of peak torque.
How fast is the PR20-102-130-HS?
It has a no load output speed of 150 rpm through a 20:1 planetary gearbox.
What encoder does the PR20-102-130-HS use?
It uses a 17 bit encoder and offers repeatability of 0.1° or better.
How much does the PR20-102-130-HS weigh?
The module weighs 1.2 kg and measures Ø102 x 59 mm.
What is the difference between the PR20-102-130-HS and PR21-100-140-HS?
Both weigh 1.2 kg. The PR20 is faster (150 rpm vs 130 rpm), has a 17 bit encoder and a shorter housing, while the PR21 offers more torque (140 Nm vs 130 Nm).
How much does the Xynova PR20-102-130-HS cost?
Pricing is by quote. Request a quote on this page for current price and cost for your quantity.
Where can I buy the Xynova PR20-102-130-HS?
You can buy it right here on this page. Add it to your quote and our team will follow up with pricing and availability.
Summary
The Xynova PR20-102-130-HS combines 150 rpm output, 17 bit feedback and 130 Nm of peak torque in a slim 1.2 kg module, giving humanoid arms and torsos the speed and positional detail that precise, natural motion depends on. If you are ready to buy responsive joint modules for your next robot, request a quote on this page for current price and availability.