BrainCo Revo 1 Intelligent Dexterous Bionic Hand
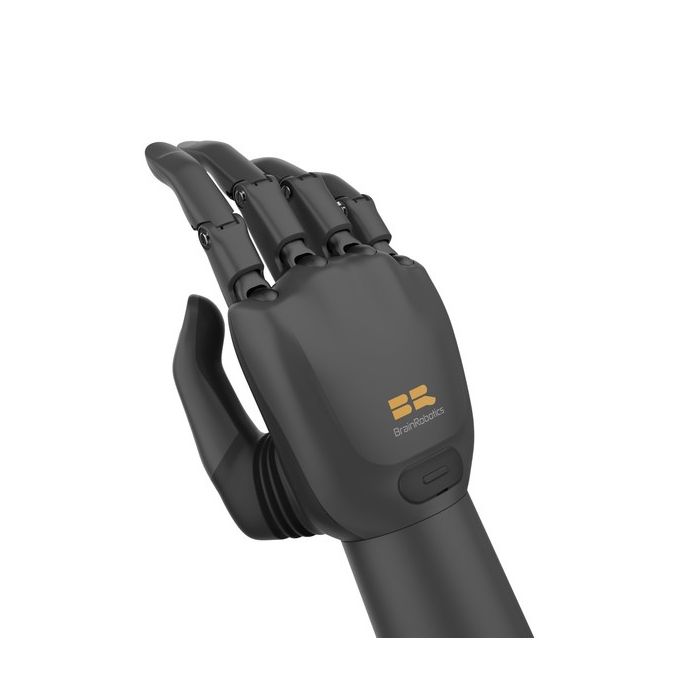
The BrainCo Revo 1 Intelligent Dexterous Bionic Hand is a robotic dexterous hand platform from BrainCo, a brain-computer-interface and human-machine-interface company that publicly lists “BrainCo Bionic Dexterous Hand Revo1” among its product lines on its official website. BrainCo positions itself as a company working across bionic hands, bionic knees, neurotechnology, and AI-oriented robotics solutions.
In stock
- BRAND:
- BRAINCO
- PART #:
- Intelligent Dexterous Bionic Hand
- ORIGIN:
- China
- Warranty:
- 12 MONTHS
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Dexterous-Bionic-Hand
BrainCo Revo 1 Intelligent Dexterous Bionic Hand
Most discussions of robotic hands begin with the fingers; the more revealing place to begin is the moment a finger stops. The BrainCo Revo 1 Intelligent Dexterous Bionic Hand is built around that moment, with a stall behaviour that pauses and then resumes gripping, and with a start-up routine that finds its own position before it accepts a command. It is a biomimetic hand with 6 active joints and 10 degrees of freedom, and its character lies in how it handles contact.
The product is available through this page, by quotation.
Background
BrainCo and the idea of the hand as an interface
BrainCo is a company associated with brain-computer interfaces and human-machine interaction. That lineage shapes how its hands are understood: not as isolated grippers, but as the mechanical end of a chain that runs from human intention to physical movement. The Revo 1 is the first generation in a family that, in this catalogue, also includes the Revo 2 and Revo 3 hands.
For a buyer, this matters mainly in terms of the surrounding tools. The hand is intended to be driven by software that an integrator writes or adapts, and the manufacturer supplies a C SDK and a Python SDK for that purpose. Teams who prefer to work in either language therefore have a starting point.
Positioning of the Revo 1 and its variants
The Revo 1 is offered in public hardware variants named Revo 1 Basic and Revo 1 Advanced, and tactile sensing depends on the SKU. The sources name three models: the Revo 1 Basic (MRL1/MRR1), the Revo 1 Basic Touch (MTL1/MTR1) and the Revo 1 Advanced (MEL2/MER2). The model codes distinguish the left-hand and right-hand versions, and the Touch version is the one named for tactile sensing.
The thumb has two active degrees of freedom, abduction/adduction and flexion/extension. Each of the other four fingers has one active degree of freedom for flexion/extension and one passive degree of freedom for flexion/extension. The arrangement lets the fingers conform to an object rather than clamp it, and the thumb can work in opposition to them. Further hands in the family are listed in the BrainCo Revo 1 category.
Technical Specifications
| Specification | Value |
|---|---|
| Active joints | 6 |
| Degrees of freedom | 10 |
| Thumb | 2 active degrees of freedom (abduction/adduction, flexion/extension) |
| Other four fingers | Each 1 active and 1 passive degree of freedom for flexion/extension |
| Maximum hand load | 30 kg |
| Five-finger grip force | 50 N |
| Supply voltage (Basic) | 9.5 ~ 28 V |
| Default device ID | 1, adjustable within 1 - 254 |
| SDKs | C SDK and Python SDK |
Specifications as published by the manufacturer; confirmed against the datasheet at quotation. The manufacturer has not published the weight, the dimensions, the IP rating, the contents of the box or the operating noise; they are confirmed at quotation.
What does turbo mode do on the Revo 1?
When a finger stalls against an object, it pauses for the configured stall duration and then continues gripping at 500 ms intervals. In practice, the hand does not simply stop at first resistance, nor does it press continuously. It re-applies its grip in measured steps, which suits objects that settle or shift slightly while being held.
The behaviour is a setting to be configured, so an integration team can tune the stall duration to the task. It is worth testing against the real objects of an application before it is relied upon.
What happens when the Revo 1 is powered on?
After power-on the hand runs a position calibration sweep automatically, and all of the fingers move while it does so. The hand therefore needs clear space around it at start-up, and any fixture or object placed in the fingers' path may be disturbed. Cell designers should include this sweep in the start-up sequence of a workstation.
Each hand also carries a device ID. The default is 1, and it can be changed within the range 1 - 254, which allows more than one hand to be told apart in a single installation.
Who is the BrainCo Revo 1 for?
Research laboratories are the most obvious buyers, particularly those studying manipulation, grasp planning or human-machine interaction and wanting a hand with open software tooling. Universities teaching robotics can use it as a practical example of an underactuated, multi-finger end-effector.
Integrators building demonstrators or prototype assistive devices form a second group. Buyers who need tactile sensing should look at the Touch version or confirm the SKU at quotation, since tactile options differ between models. Those who want a later generation can compare the Revo 2 Touch or the Revo 3-21 Basic. Buyers working in clinical research may also browse the Medical Robots category.
What is the BrainCo Revo 1 used for?
- Manipulation research: studying how a multi-finger hand adapts its hold to different objects.
- Teaching: giving students a working example of a biomimetic hand and its control software.
- Assistive-technology development: prototyping devices that must act on human intent.
- Robot-arm end-effector trials: fitting a dexterous hand to an arm for pick-and-place experiments.
- Humanoid platform work: providing a hand for projects that aim at human-like manipulation.
- Software development: writing and testing grasp routines with the C or Python SDK.
Pricing and Availability
No price is shown on this page. A quotation is the way to proceed, and it sets out the variant, the left or right model and the configuration you require. Delivery, customs and support are arranged with the quotation. The BrainCo Revo 1 Intelligent Dexterous Bionic Hand is available on this page.
Frequently Asked Questions
How many degrees of freedom does the Revo 1 have?
It has 6 active joints and 10 degrees of freedom. The thumb has two active degrees of freedom, and each of the other four fingers has one active and one passive degree of freedom.
What load can the hand bear?
The maximum hand load is 30 kg, and the five-finger grip force is 50 N. These are two different measures.
Which variants exist?
The public variants are Revo 1 Basic and Revo 1 Advanced, with tactile sensing depending on the SKU. The Basic, Basic Touch and Advanced models carry different codes for left and right hands.
Which software development kits are available?
A C SDK and a Python SDK are available. Both are suited to custom integration work.
Does the hand calibrate itself?
Yes. It runs a position calibration sweep after power-on, and all fingers move during it.
Can the device ID be changed?
The default device ID is 1, and it can be set anywhere within 1 - 254.
Where can I buy the BrainCo Revo 1 and what does it cost?
It is available through this page by quotation. The cost depends on the variant and configuration, and is given in the quotation.
Summary
The Revo 1 is a hand that reveals itself at the point of contact: a thumb with two active movements, fingers that pair a driven joint with a passive one, a stall routine that resumes gripping in steps, and a calibration sweep at start-up. Its published figures, a 30 kg hand load and a 50 N grip force, describe a hand made to hold carefully. For a quotation on the variant you need, this page is the starting point.