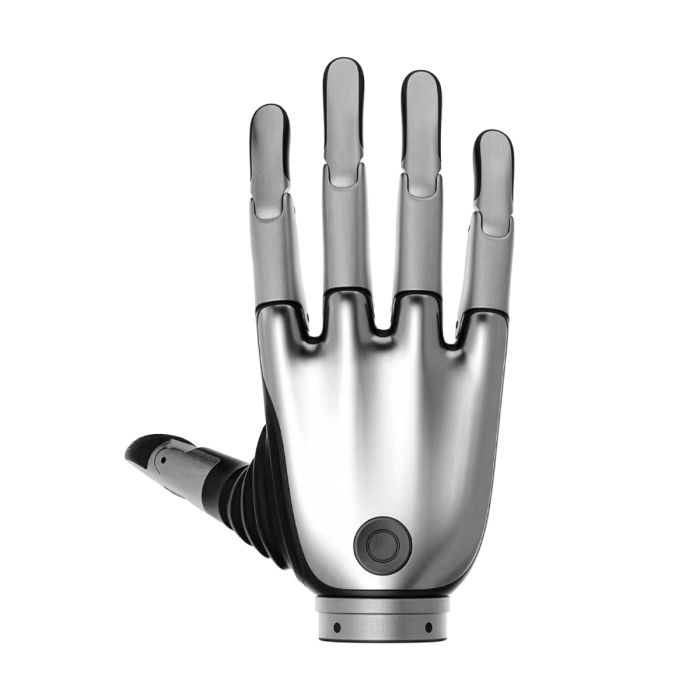
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
In stock
- BRAND:
- BRAINCO
- MODEL:
- REVO 2 TOUCH (LEFT)
- PART #:
- XTL
- ORIGIN:
- China
- AVAILABILITY:
- SUBJECT TO AVAILABILITY
- SKU:
- BrainCo-Revo-2-Touch-Left
Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL)
Ask a manipulation team where a trial tends to go wrong and the answer is seldom the arm. The arm reaches; the hand must then decide how far each finger closes, how firmly it holds and when it stops. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is aimed at that final stage of a task, where reaching turns into handling. The maker's published material describes the Revo 2 as a bionic dexterous hand for robot integration and research. This listing covers the tactile version of that second-generation hand, in its left-hand configuration.
The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is available through this page, by quotation.
Background
BrainCo and the Revo line
BrainCo is generally associated with bionic and neurotechnology products, and the Revo name covers its dexterous robot hands. The Revo 2 is the second generation of that line and follows the earlier Revo 1. The published sources set out three versions of the Revo 2: Basic (version codes XRL/XRR), Pro (XEL/XER) and Touch (XTL/XTR). In each pair, the first code is the left hand and the second the right. The whole family can be browsed under BrainCo Revo 2.
Where the Touch version sits
The source material refers to the Touch as the tactile version of the second-generation hand. According to the published documentation, it shares the advanced interface arrangement of the Pro: three communication interfaces, located below the wrist. The Touch therefore sits at the top of the Revo 2 range, intended for work in which the hand's contact with an object matters as much as its movement. The detailed specification of the tactile sensing itself has not been published in the sources available to us. Sensor type, layout and fingertip force resolution are confirmed against the datasheet at quotation.
Technical Specifications
| Specification | Value |
|---|---|
| Product type | Bionic dexterous hand for robot integration and research |
| Version code | XTL (left hand); XTR is the right-hand counterpart |
| Degrees of freedom | 11, of which 6 are active |
| Thumb | Two active DOF for abduction and adduction; one passive flexion/extension DOF |
| Other four fingers | Each with one active and one passive flexion/extension DOF |
| Pinch force | ≥15N |
| Control precision | 0.1° |
| Control | Closed-loop servo control; custom gesture definitions |
| Protections | Current, stall, high temperature and collision |
| Communication interfaces | RS485, CAN FD, EtherCAT |
| Interface location | Below the wrist |
| SDK support | Linux, Windows, ROS |
| Default device ID (left hand) | 126 |
| Tactile sensing details / fingertip force resolution | Not published; confirmed at quotation |
| Weight and payload | Not in the verified sources; confirmed at quotation |
| IP rating | Not published; confirmed at quotation |
| Cable length | Not published; confirmed at quotation |
| Material | Not published; confirmed at quotation |
| Box contents | Not published; confirmed at quotation |
These specifications are given as published by a single source and are confirmed against the manufacturer's datasheet at quotation.
What does the Touch version add over the Basic and Pro?
The published sources set the three versions apart in two ways. The first is the name: the Touch is the tactile version, so it is the variant for teams whose work depends on contact information. The second is the interface: according to the source, both the advanced (Pro) and tactile (Touch) versions support RS485, CAN FD and EtherCAT, with the connector below the wrist. That matters to an integrator choosing between fieldbuses on an existing robot.
What the sources do not provide is a figure-by-figure comparison of the tactile hardware. The pinch force of ≥15N, the control precision of 0.1° and the joint layout are reported for the Revo 2 hand without being tied to a single version. They should be read as published values for the family and checked against the Touch datasheet. A buyer whose project does not need tactile data may find the BrainCo Revo 2 Pro Dexterous Left Hand (XEL) the more proportionate choice. The BrainCo Revo 2 Basic Left Dexterous Bionic Hand (XRL) is the entry point to the range.
How does the hand fit into a robot control system?
The reported architecture is built around integration rather than stand-alone use. Control is closed-loop servo control, so each active joint is driven to a commanded position and held there. Custom gesture definitions allow a team to store grasp postures and recall them, rather than streaming every joint target from the host. Protections for current, stall, high temperature and collision are described as built in. These matter when a research programme leaves the hand cycling through repeated trials with little supervision.
On the software side, the published material lists SDK support for Linux, Windows and ROS workflows. Most university and industrial robotics stacks can therefore address the hand without bespoke drivers. The default device ID for the left hand is given as 126, and the right hand defaults to 127. A bimanual rig can therefore place both hands on a shared bus without an addressing conflict at first power-up. As with every figure on this page, the ID and the bus behaviour should be confirmed against the datasheet at quotation.
Who is the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) for?
The first audience is the research laboratory: groups studying grasping, in-hand manipulation and contact-rich tasks, for whom a tactile version is the reason to choose this hand at all. The second is the humanoid and mobile-manipulator integrator who needs a left hand that connects over an industrial fieldbus and runs under ROS. Teams building a two-handed platform will want to pair it with the Brainco Revo 2 Touch Biomimetic Dexterous Right Hand (XTR), so that both sides carry the same version and the same interface.
Industrial development teams evaluating dexterous end effectors form a third group. For them, the Touch is most relevant where contact data will feed into the evaluation. Where the task is mainly positional, such as pick-and-place demonstrations or gesture work, the Pro or Basic versions may suit the budget and the brief better. Teaching departments running robotics programmes may also consider the hand, since its open SDK support allows students to work from familiar operating systems.
What is the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) used for?
- Grasp research: studying how a multi-fingered hand closes on objects of differing shape and stiffness.
- Humanoid integration: fitting a dexterous left hand to a humanoid or dual-arm research platform.
- Bimanual manipulation: pairing with the right-hand Touch version for coordinated two-handed tasks.
- Learning from demonstration: collecting manipulation data for AI and machine-learning policy training.
- Gesture-based handling: storing custom gestures for repeated grasps in laboratory automation trials.
- Teaching and prototyping: giving students and engineers a ROS-ready hand for control and manipulation coursework.
Pricing and Availability
The hand is supplied by quotation, which allows the configuration, the left- or right-hand pairing and the communication interface to be confirmed before an order is placed. Delivery, customs and technical support are arranged with the quotation. Specifications that have not yet been published, including the tactile sensing details, IP rating, cable length, material and box contents, are confirmed in the same exchange. A quotation for the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) can be requested directly from the form available on this page.
Frequently Asked Questions
Is the XTL a left or a right hand?
The XTL is the left hand of the Touch version; its right-hand counterpart carries the code XTR. Both belong to the tactile version of the Revo 2.
Which communication interfaces does it support?
According to the published source, the Pro and Touch versions support RS485, CAN FD and EtherCAT. The interface is located below the wrist.
Can the hand be used with ROS?
The published material lists SDK support for Linux, Windows and ROS workflows. Version compatibility with a given ROS distribution should be checked at quotation.
What is the default device ID of the left hand?
The source gives a default ID of 126 for the left hand and 127 for the right. This allows a pair to share a bus without readdressing.
What protections does the hand include?
The hand is reported to include protections for current, stall, high temperature and collision. These sit alongside closed-loop servo control and custom gesture definitions.
Are the IP rating, material and box contents published?
No. The IP rating, material, cable length, box contents and fingertip force resolution have not been published by the sources available. They are confirmed at quotation.
Where can I buy the Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) and what does it cost?
The hand can be ordered through this page by quotation. The quotation sets out the cost for your configuration, together with delivery, customs and support.
Summary
A robot's arm brings it to the object; its hand determines what happens next. The Brainco Revo 2 Touch Biomimetic Dexterous Left Hand (XTL) is the tactile version of BrainCo's second-generation hand, built for that moment of contact. The published specification describes a hand with 11 degrees of freedom, six of them active, a pinch force of ≥15N and a control precision of 0.1°. It connects over RS485, CAN FD or EtherCAT and is supported under Linux, Windows and ROS. Several details a careful buyer will want, from the tactile sensor specification to the IP rating, are not yet published and are settled at quotation. For a laboratory or integrator ready to give a robot a hand capable of real handling, this page is the starting point.
Specifications
General
Physical
Mobility
Performance
Connectivity
Software
Hand
What's included
Videos